Trainable Pointwise Decoder Module and Virtual Range Image-Guided Copy-Rotate-Paste Augmentation for Point Cloud Segmentation
Abstract
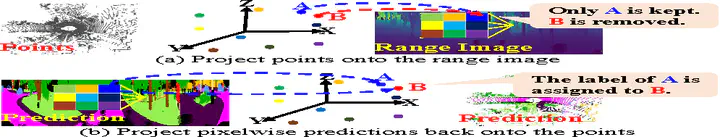
Point cloud segmentation (PCS) aims to make per-point predictions, enabling robots and autonomous driving cars to understand their environments. The range image is a dense representation of a large-scale outdoor point cloud. Segmentation models built upon the range image commonly execute efficiently. However, the projection of the point cloud onto the range image inevitably leads to dropping points because multiple points could be projected onto the same image location, but only one point is kept. More importantly, it is challenging to assign correct predictions to the dropped points with different classes from the kept point class. Besides, existing post-processing methods, such as $K$-nearest neighbor ($K$NN) search and kernel point convolution (KPConv), cannot be trained with the models in an end-to-end manner or cannot process varying-density outdoor point clouds well, thereby enabling the models to achieve sub-optimal performance. To alleviate this problem, we propose a trainable pointwise decoder module (PDM) as the post-processing approach, which gathers weighted features from the neighbors and then makes the final prediction for the query point. In addition, we introduce a virtual range image-guided copy-rotate-paste (VRCrop) strategy in data augmentation. VRCrop constrains the total number of points and eliminates undesirable artifacts in the augmented point cloud. Also, VRCrop is model-agnostic and can be easily employed in various PCS models. With PDM and VRCrop, existing range image-based segmentation models consistently surpass their counterparts on the SemanticKITTI, SemanticPOSS, and nuScenes datasets.
Bike Chen
Postdoctoral Researcher
My research interests include semantic image segmentation, point cloud segmentation, SLAM, LLM, and VLA.
Antti Tikanmäki
Research Group Leader
My research interests include mobile robots and autonomous systems.