Abstract
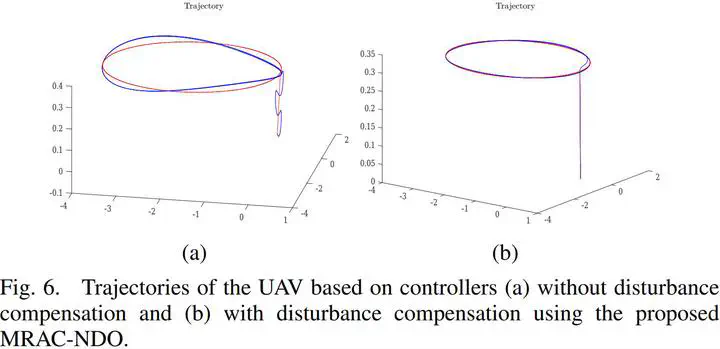
Unknown disturbances are one of the most critical factors impacting control performances, and the design of globally convergent disturbance observers for estimation of disturbances in real-time plays an important role in improving the performance of control systems. This work presents the design of a novel disturbance observer based on model reference adaptive control to relax the restrictive gain conditions in conventional nonlinear disturbance observer design. The proposed Model Reference Adaptive Control-based Nonlinear Disturbance Observer (MRAC-NDO) features a simple structure with theoretically guaranteed global convergence for estimating unknown disturbances appearing in affine systems. The proposed strategy is applied to unmanned aerial vehicles (UAVs) based on cascaded control incorporated by MRAC-NDO disturbance compensation. Numerical results validate the effectiveness of the proposed solution.
Antti Tikanmäki
Research Group Leader
My research interests include mobile robots and autonomous systems.